

Robotics
How robots are designed, controlled and programmed so machines can sense and act in the physical world.
39 articles published
Viewed 0/39
Articles by level
This list is not complete and has no required order. Pick the articles you need at the level that suits you.
Starter
8 articlesViewed 0/8 Starter
What Is a Robot?
What a robot is, what jobs robots do and what abilities they need to work. A first article for beginners, explained with familiar examples.
4 min read Starter
How Do Robots Use Sensors to Understand Their Surroundings?
Robots sense the world around them with sensors such as cameras, lasers and touch sensors. This article explains what each kind does, for beginners.
4 min read Starter
Where Do We Encounter Industrial Robots?
Where industrial robots work and what jobs they do, from large factories to small workshops. A starter article for complete beginners.
4 min read Starter
What Are the Main Parts of a Collaborative Robot?
What the arm, joints, sensors, controller and end tool of a collaborative robot each do. A starter article that names these parts for beginners.
3 min read Starter
Why Do Service Robots Matter?
Service robots do useful tasks for people at home, in hospitals and even in space. This article shows beginners why they are worth understanding.
4 min read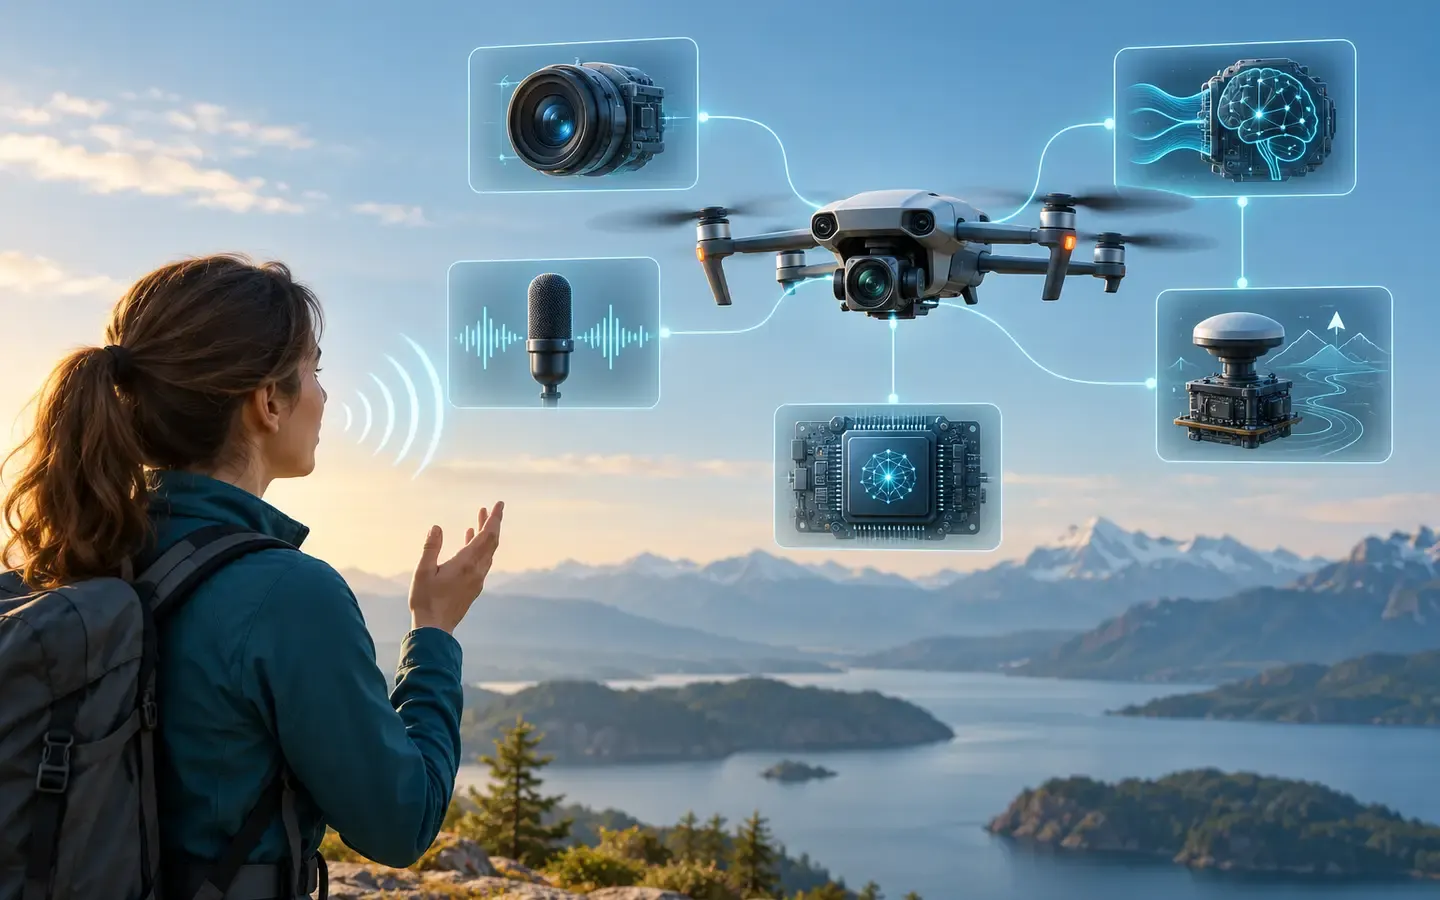 Starter
Overview of a Voice-Controlled AI Camera Drone
Trace a proposed architecture from speech and images through target checks to flight control and feedback.
5 min read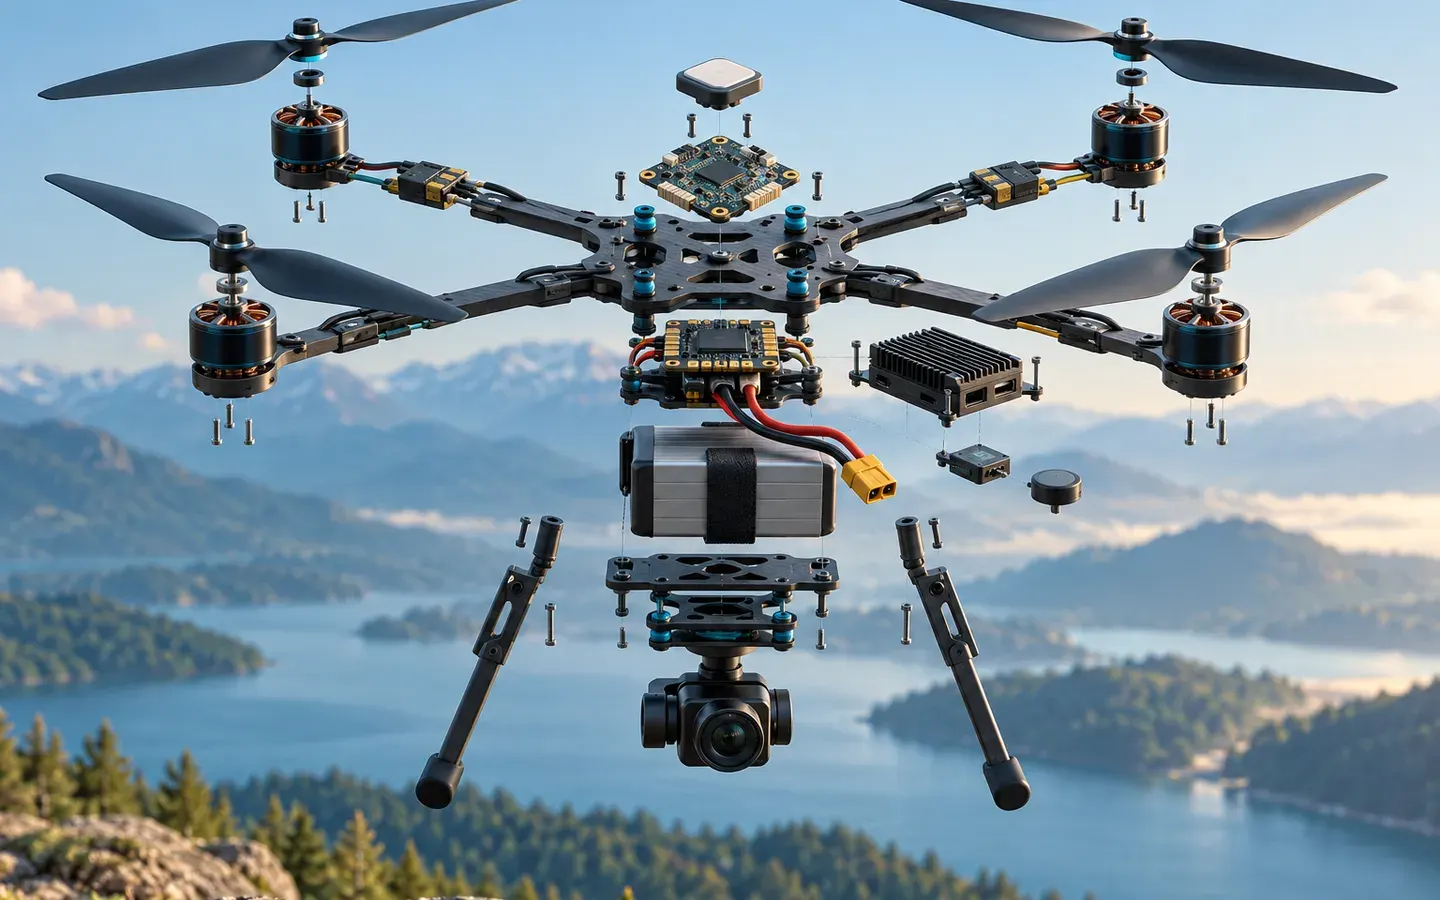 Starter
What Are the Main Parts of a Multirotor Drone?
Identify the frame, battery, sensors, controller, ESCs, motors and propellers through their power and command paths.
4 min read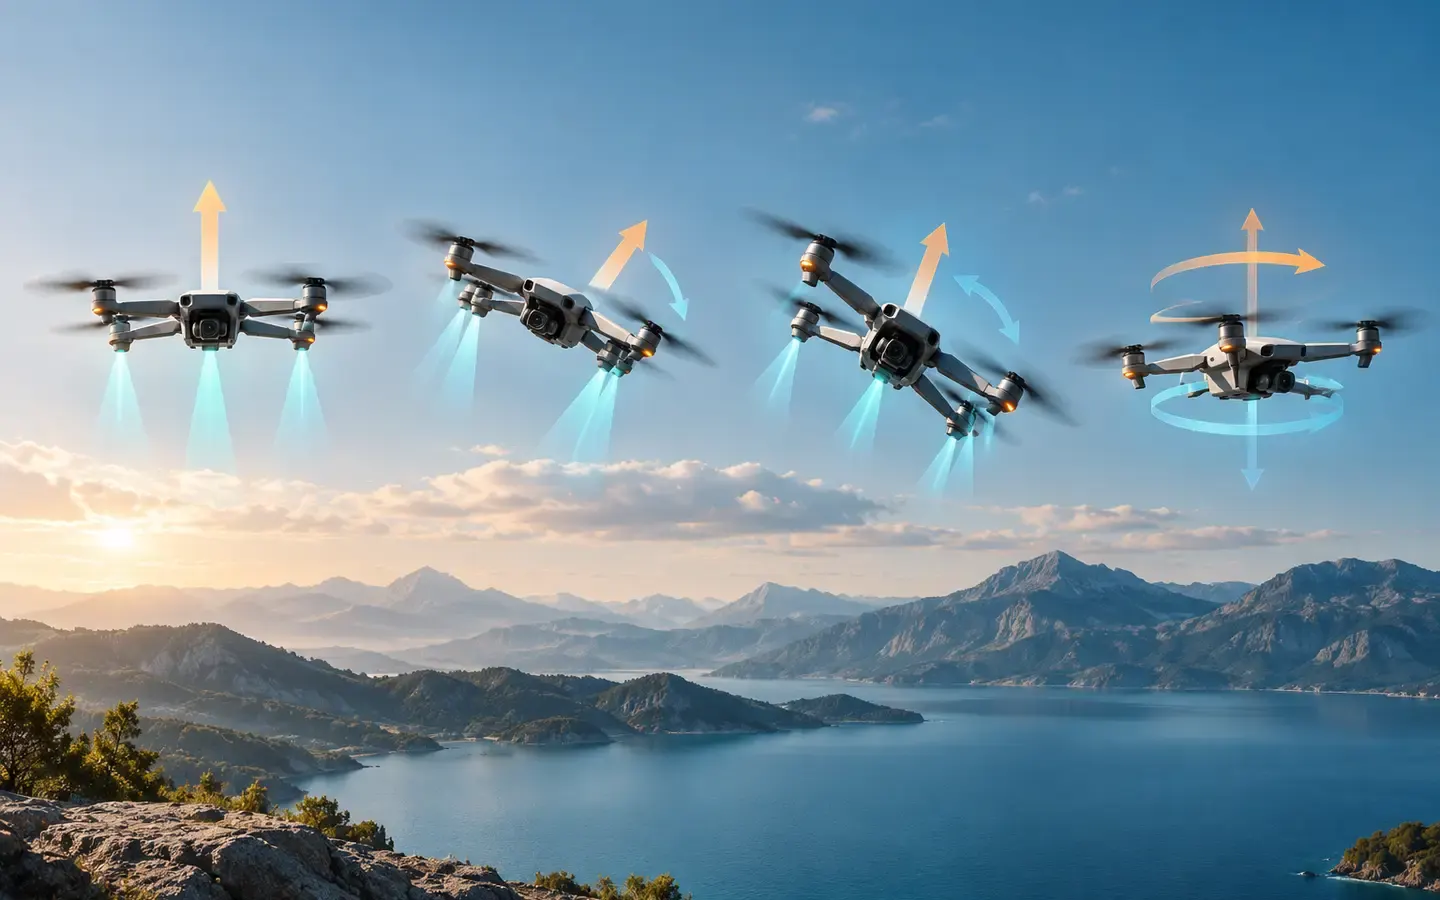 Starter
How Does a Quadcopter Rise, Tilt and Turn with Four Rotors?
Explains how total thrust, rotor force differences and reaction torque create quadcopter motion.
7 min read


Basic
9 articlesViewed 0/9 Basic
How Do a Brushless Motor, ESC and Propeller Work Together?
Trace how an ESC commutates a brushless motor and how a propeller turns rotation into thrust.
6 min read Basic
What Does a Flight Controller Do in Each Control Loop?
Trace a control loop from sensor samples and state estimates through error, actuator commands and feedback.
6 min read Basic
How Does a Drone Use Its IMU, Barometer and GPS?
Learn how an IMU, barometer, GPS, and estimator combine measurements to infer a drone’s state.
6 min read Basic
How Do Manual, Altitude and Position Hold Differ?
Compare Stabilized, Altitude and Position by what each holds, what happens when sticks are released and positioning needs.
4 min read Basic
How Does a Gimbal Keep a Camera Pointing Steady?
Explains the sensor-controller-motor loop that holds camera direction and distinguishes it from MAVLink commands.
6 min read Basic
How Does a LiPo Pack Power a Drone and Set Its Flight Time?
Trace power from battery to motors, distinguish capacity from energy and estimate duration from load.
5 min read Basic
How Can You Test Drone Commands in a Simulator?
Understand payload, total mass, weight, combined rotor thrust, and thrust margin.
6 min read Basic
What Should You Check Before a Flight?
A grouped preflight checklist for environment, vehicle, power, and controls, including how to handle unresolved checks.
6 min read Basic
What Does a Mini Mopping-Robot Fleet Include?
The four parts of a small mopping-robot fleet: robots, dock, central controller and person, plus the data and states that link them.
8 min read


Intermediate
16 articlesViewed 0/16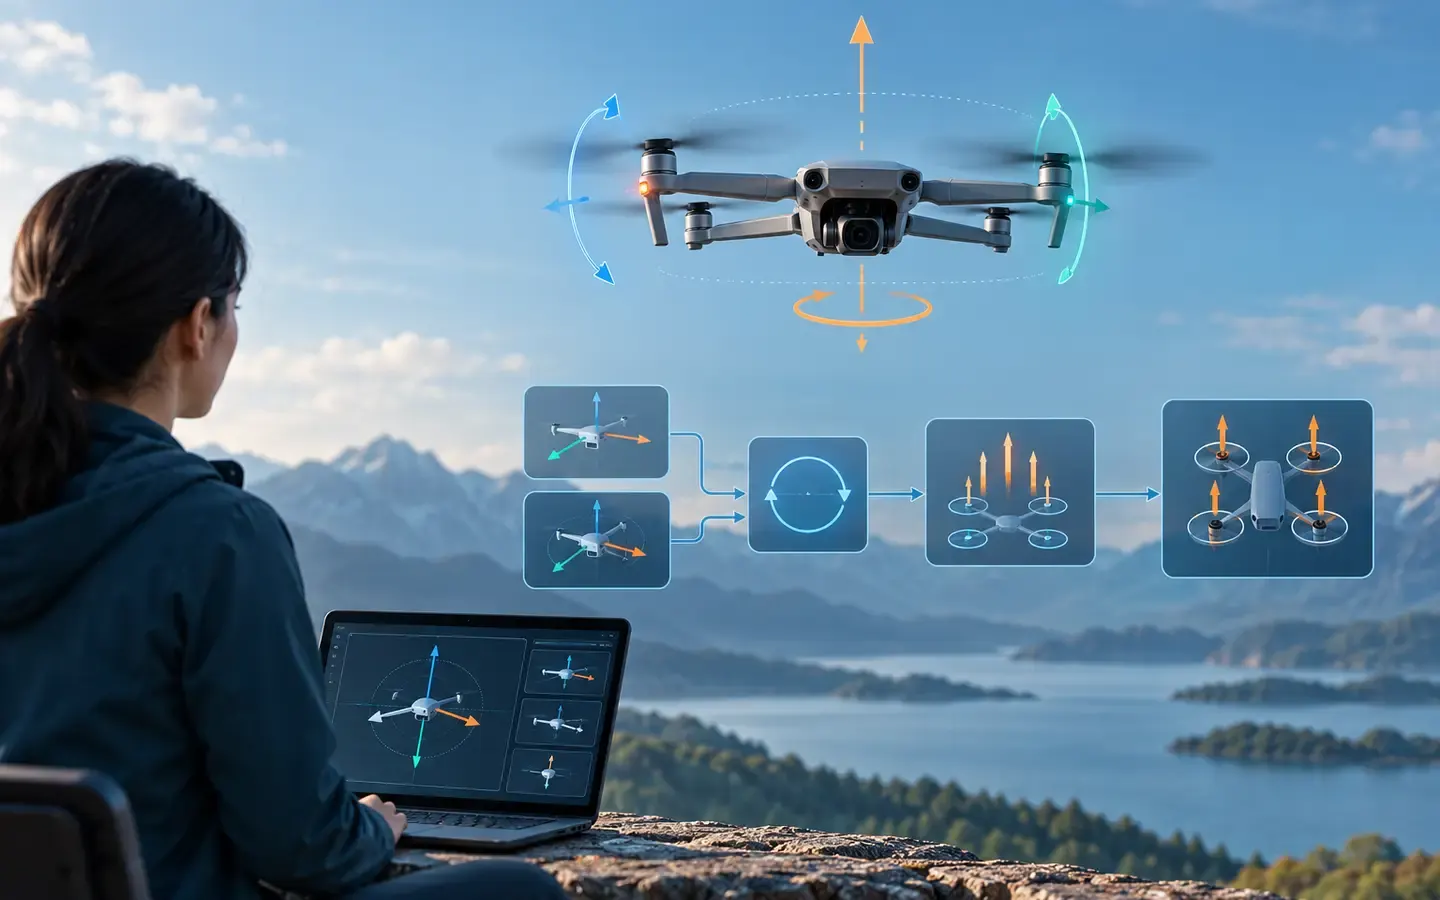 Intermediate
How Does a Drone Hold Its Attitude with a Control Loop?
Trace feedback from the IMU through attitude and rate loops to actuator commands, including noise and saturation limits.
7 min read Intermediate
How Do Weight, Payload and Thrust Relate to One Another?
Understand payload, total mass, weight, combined rotor thrust, and thrust margin.
6 min read Intermediate
How Do Drone Failsafes and Return-to-Home Work?
Trace Hold, Return, home requirements and fallback branches when positioning data is unavailable.
6 min read Intermediate
How Does a Drone Detect and Avoid Obstacles?
Explains the path from range observations to stopping or avoidance, stale-data handling and geofence limits.
7 min read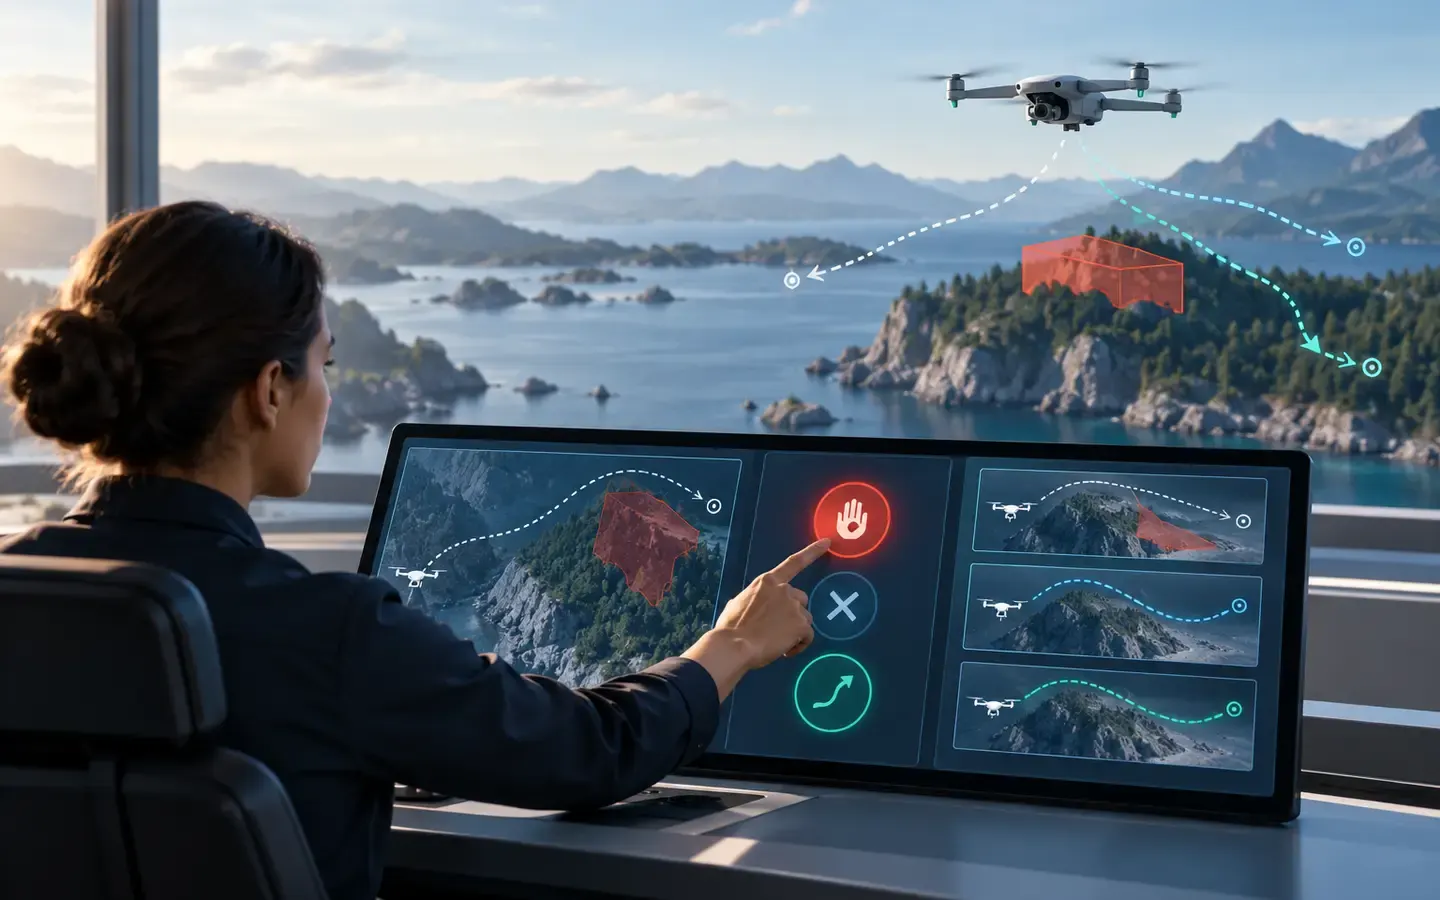 Intermediate
How Can a Human Pilot Always Override Voice and AI Commands?
Explore a proposed priority architecture, handover confirmation and the difference between cancelling AI, Return and motor stop.
6 min read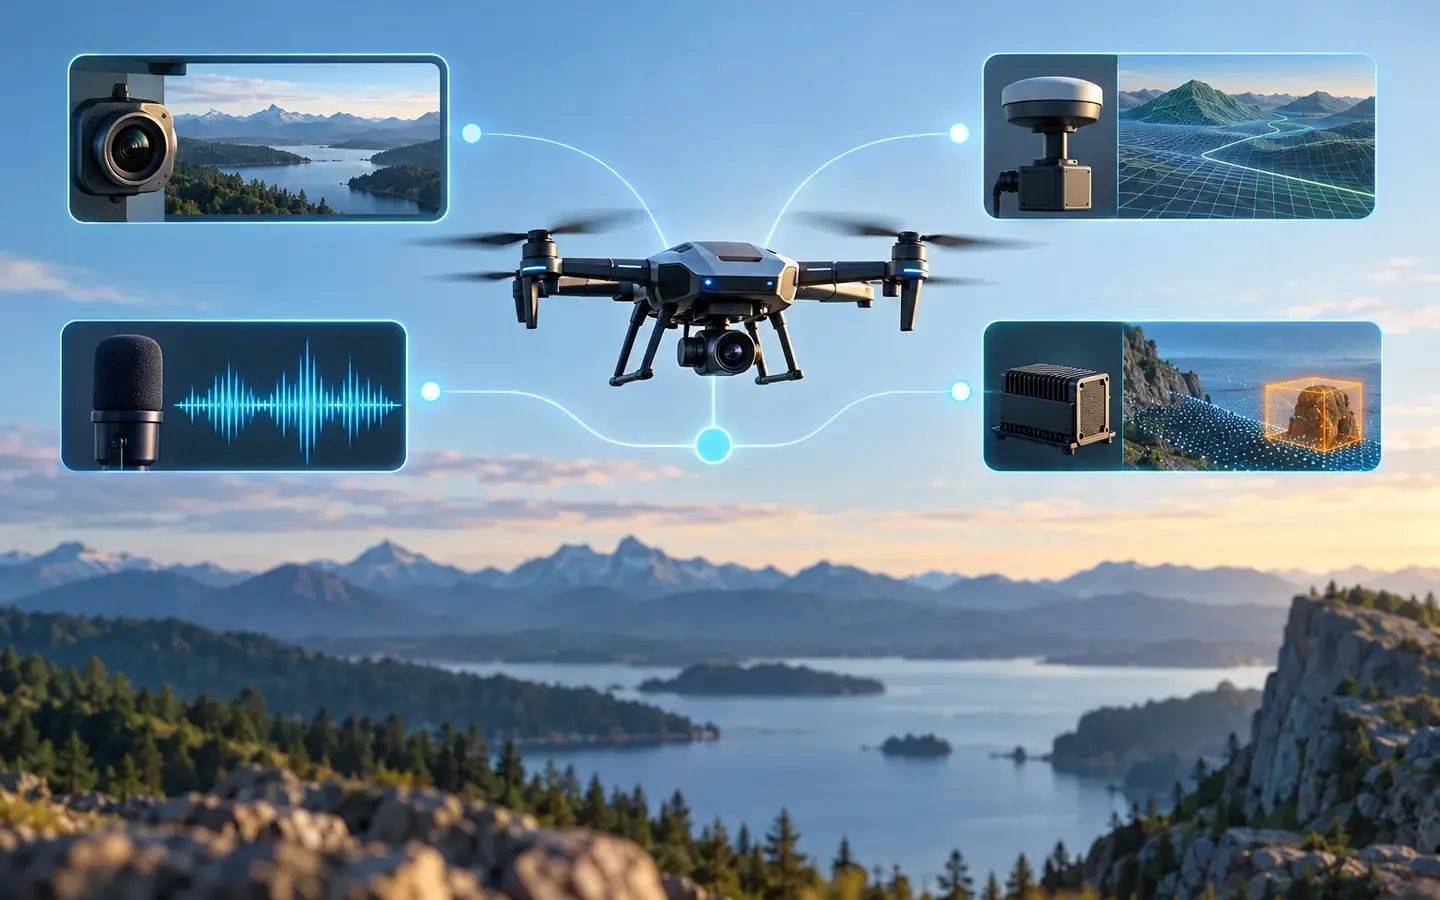 Intermediate
How Does ROS 2 Connect Voice, Vision and Flight Control?
Follow a voice command through speech recognition, vision, coordination and PX4 to see how ROS 2 connects drone software and returns task feedback.
6 min read Intermediate
Drone Camera and Microphone Privacy
Assess privacy risks from images, audio, location, and data handling, then apply the NIST framework to a drone scenario.
6 min read Intermediate
Central or Onboard Control for a Mopping-Robot Fleet?
Compare central, onboard and hybrid control for a small mopping-robot fleet on cost, latency, fault tolerance and bandwidth, then choose.
12 min read Intermediate
How Is a Mop Robot Built to Fit Under a Bed?
From bed clearance to body height: differential drive, wheels, tank, pump and battery layout, mop pad drag and how a robot escapes a jam.
7 min read Intermediate
Which Sensors Stop a Small Robot Falling or Colliding?
Cliff, bumper, time-of-flight, encoder, IMU and motor-current sensing: how each works, where it sits, how it fails and which one wins.
7 min read Intermediate
How Does a Robot Mop Clean and Leave the Floor Dry?
A damp-pad mopping robot meters water to its speed so floors dry quickly; this covers the method, its limits and an optional scent module.
7 min read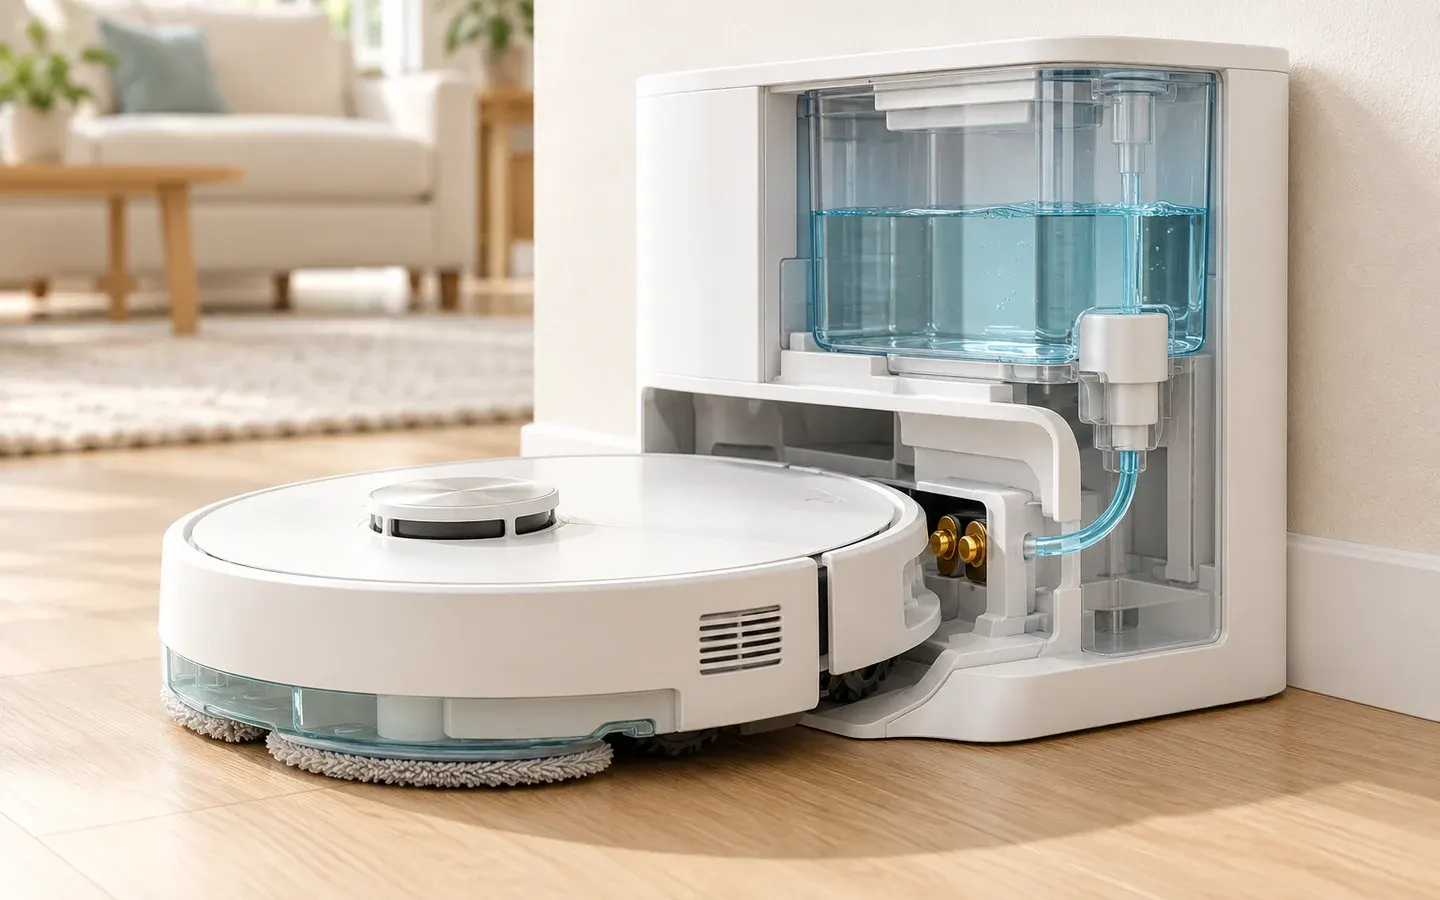 Intermediate
How Does a Dock Recharge and Refill a Mop Robot?
A mop robot docks in stages, charges through contacts, then refills its tank; this covers guidance, contact checks, water levels and sharing a dock.
7 min read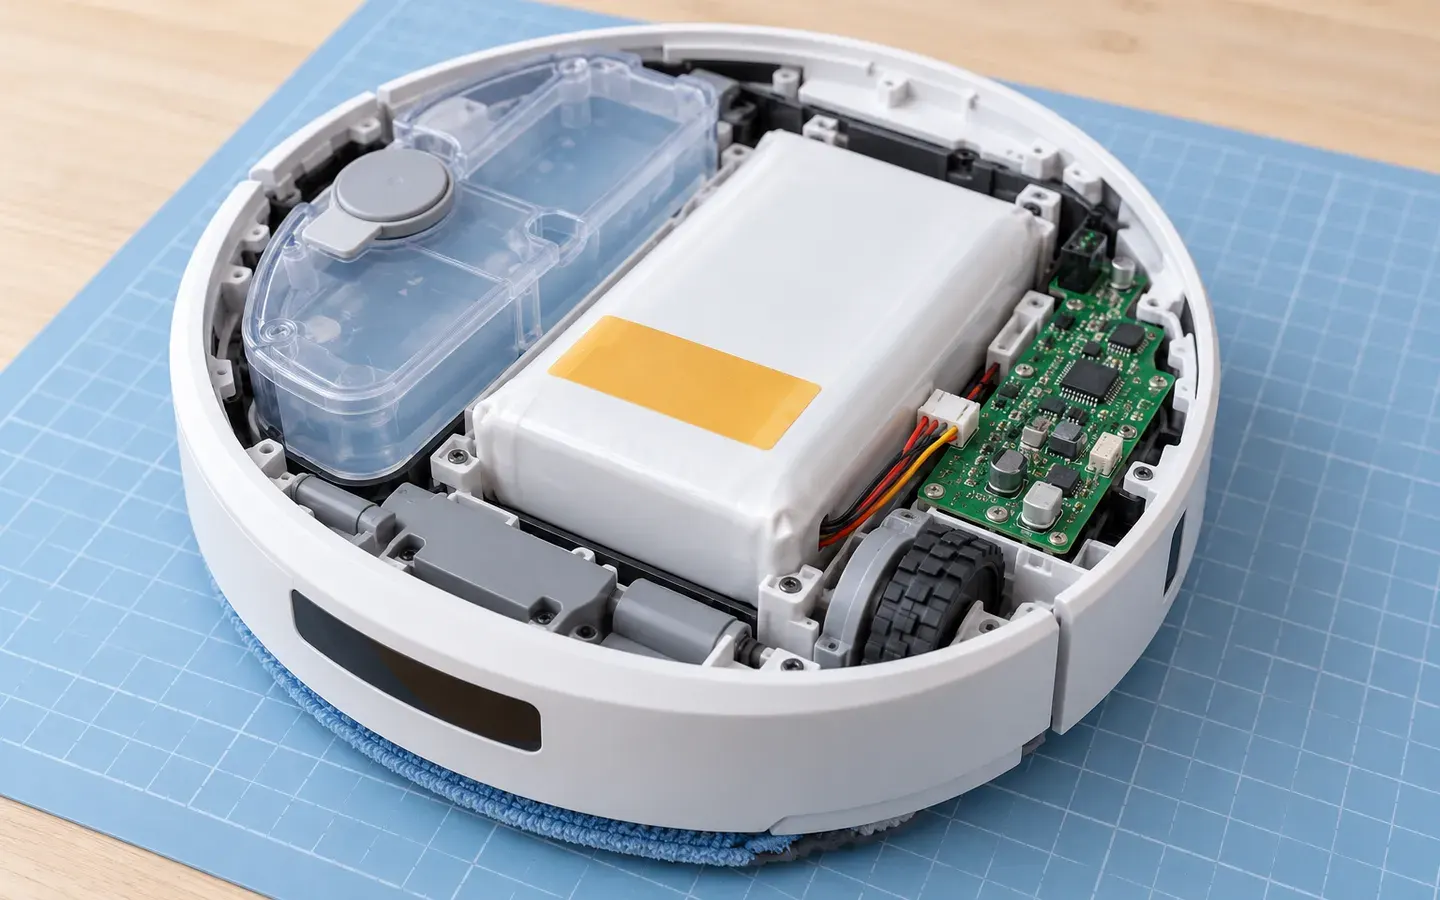 Intermediate
How Long Does a Small Mop Robot Run per Charge?
The energy budget of a small mop robot: load split, usable capacity, charge estimates and the reserve needed to reach the dock.
7 min read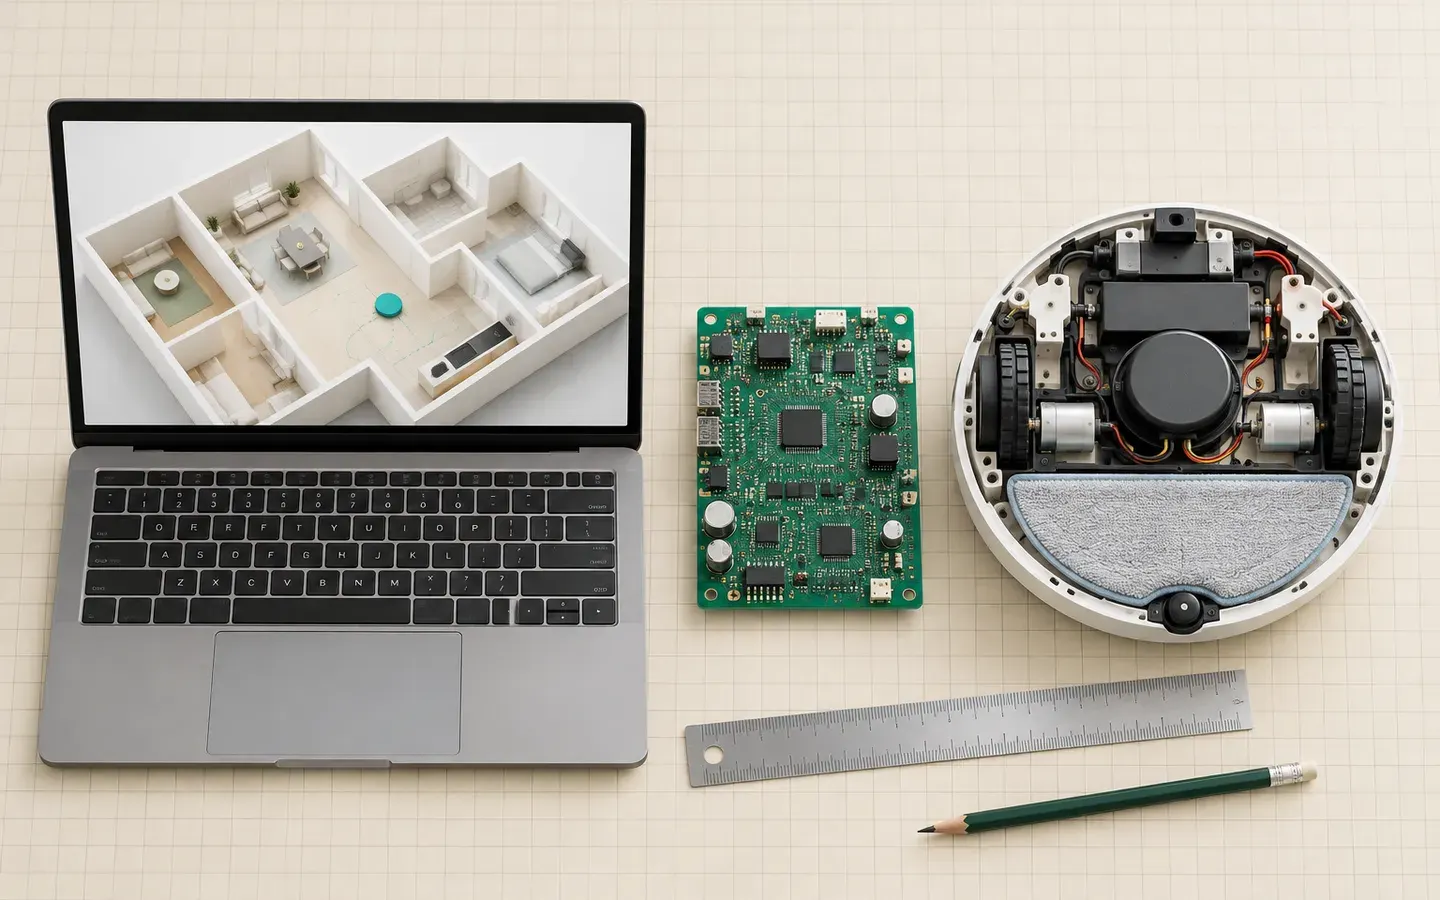 Intermediate
Which Layers of a Mop Robot Should Simulation Cover?
Four simulation layers for a mop robot: circuit, firmware, motion and fleet; what each can verify, its pass criteria and when to build a prototype.
7 min read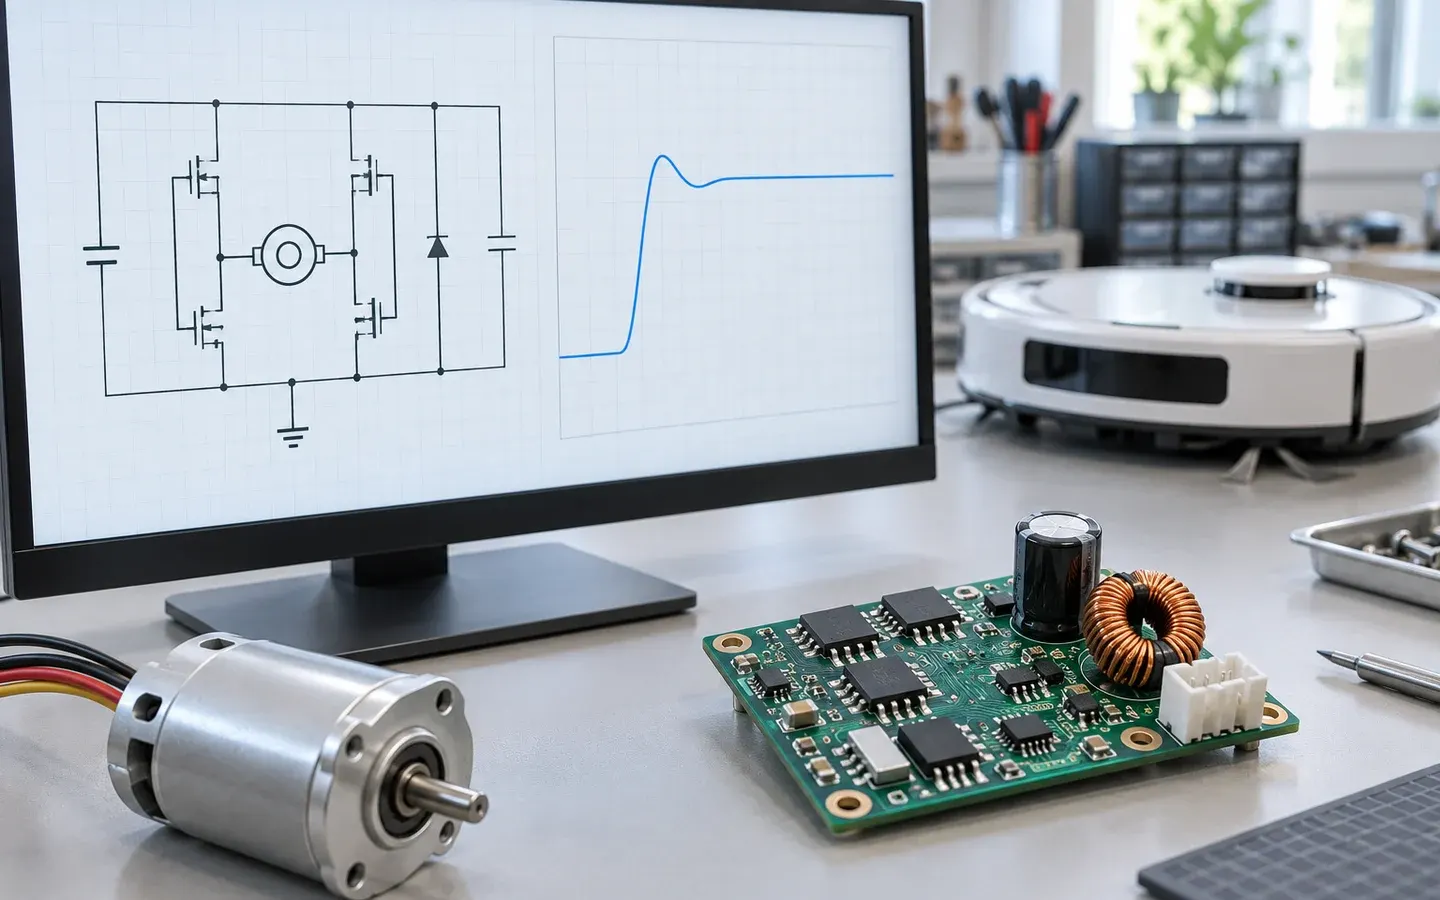 Intermediate
Which Tools Simulate a Mop Robot's Electronics?
Simulating a mop robot's circuits: SPICE tools, which circuits to test, how to read a pass or fail result and what simulation cannot replace.
7 min read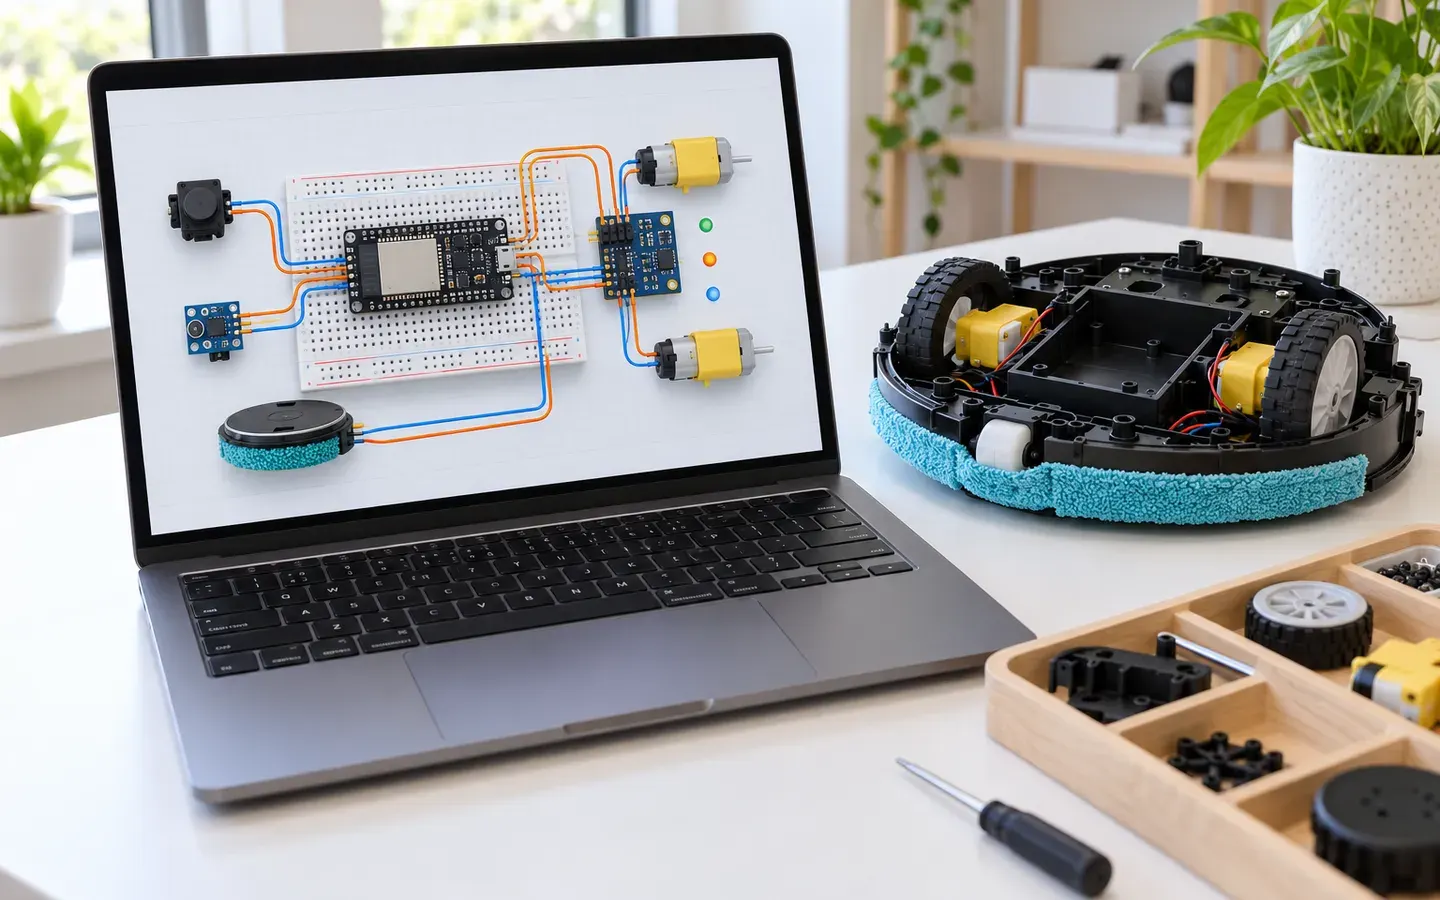 Intermediate
How Can Robot Firmware Run Before the Hardware Exists?
Three ways to test mop-robot firmware before hardware exists: host-side logic tests, microcontroller emulation and hardware-in-the-loop, and their limits.
7 min read


Advanced
6 articlesViewed 0/6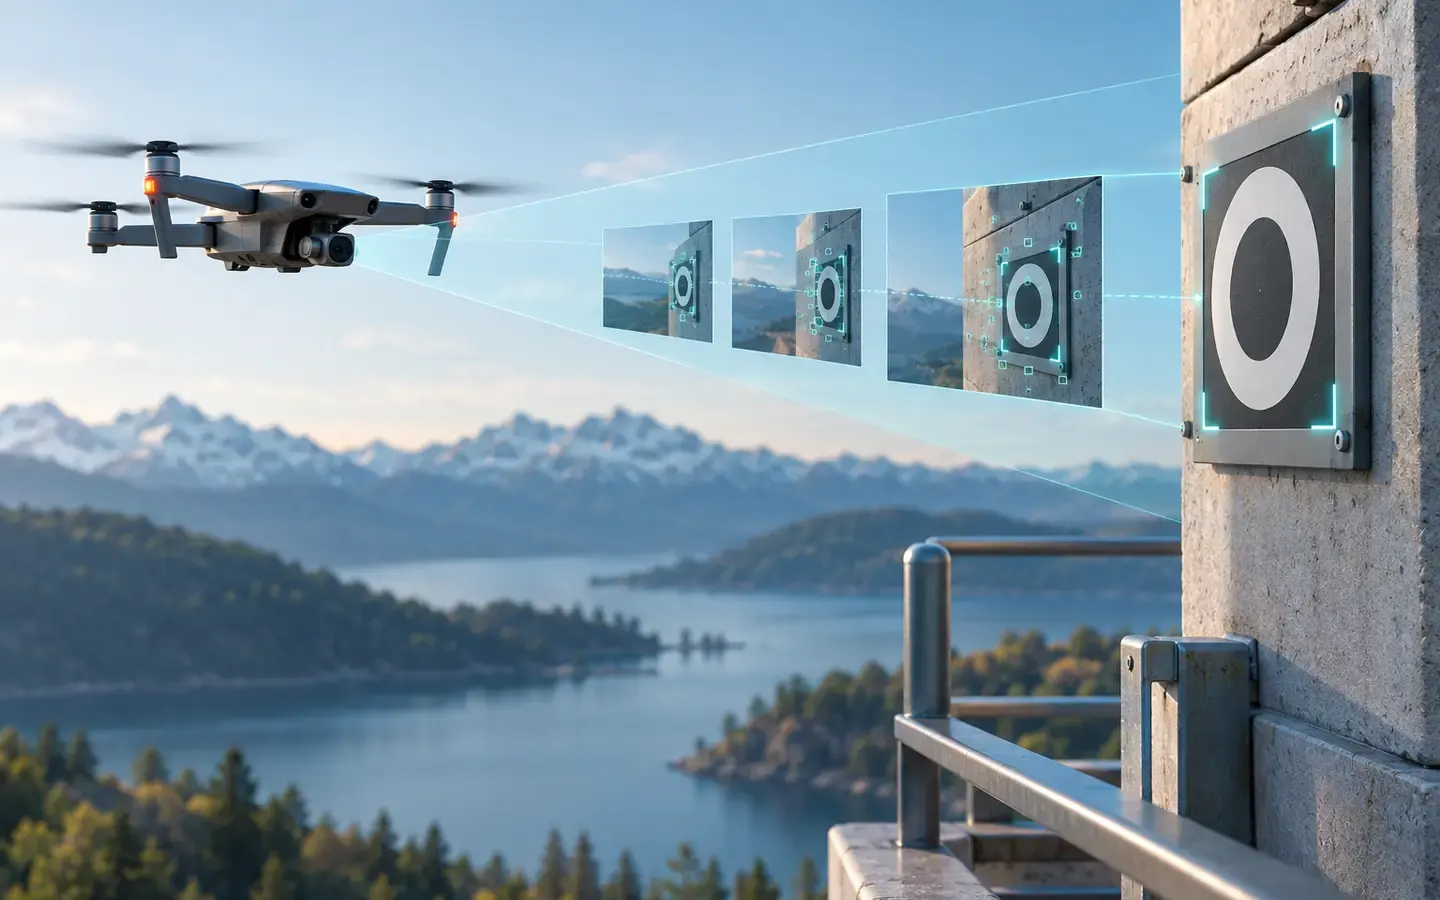 Advanced
How Does Visual Servoing Guide a Drone?
Explains how image-feature error maps to drone velocity, closes the feedback loop and compares with world-coordinate control.
8 min read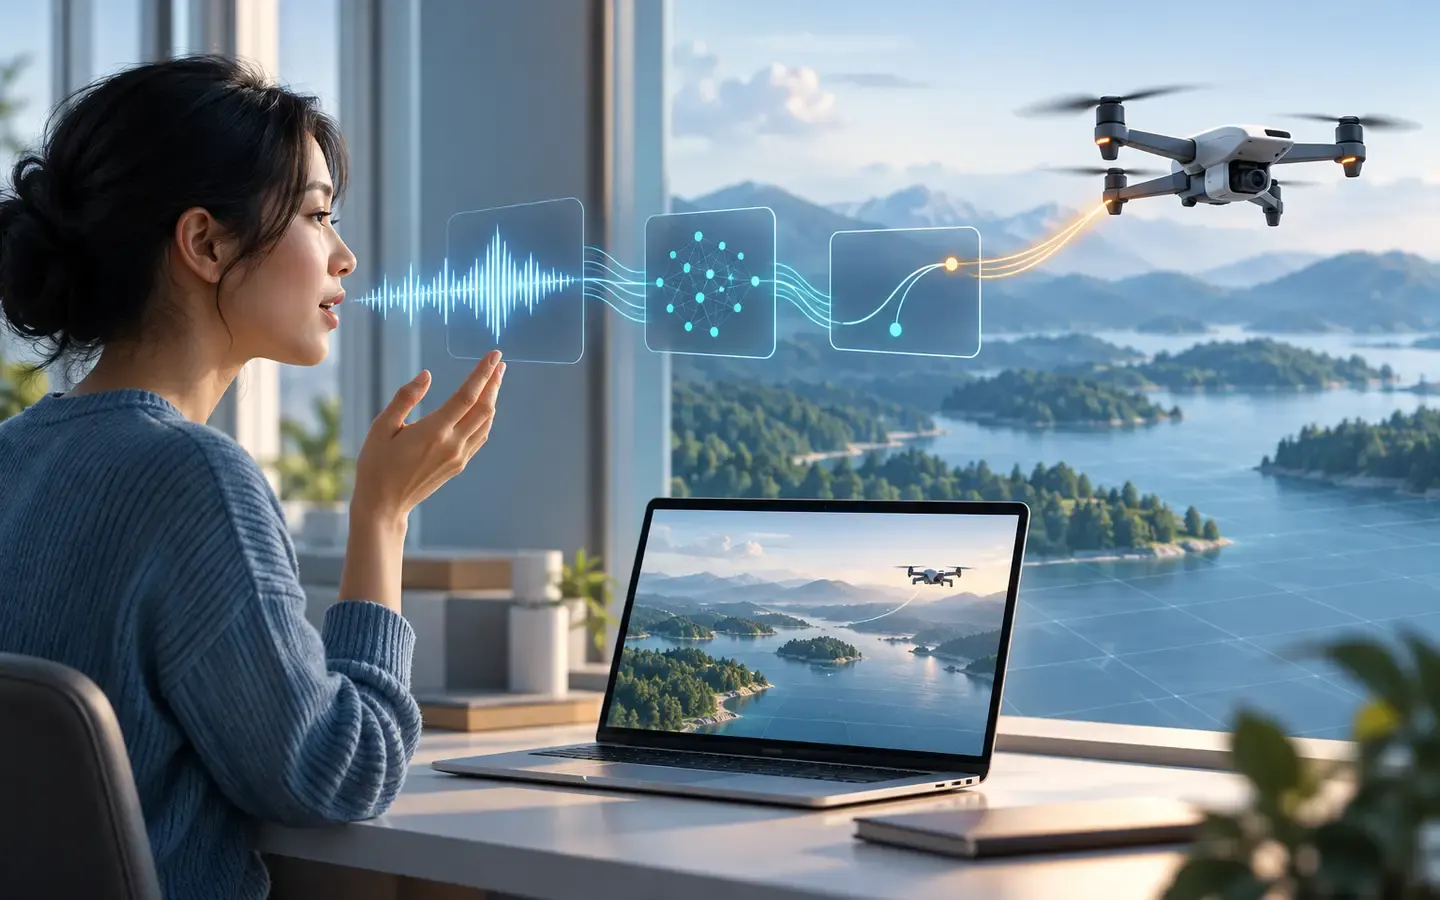 Advanced
Simulating Drone Control with Voice Commands
Learn how voice commands pass through parsing, coordination, setpoints and feedback in a simulation, with evaluation criteria and failure cases.
8 min read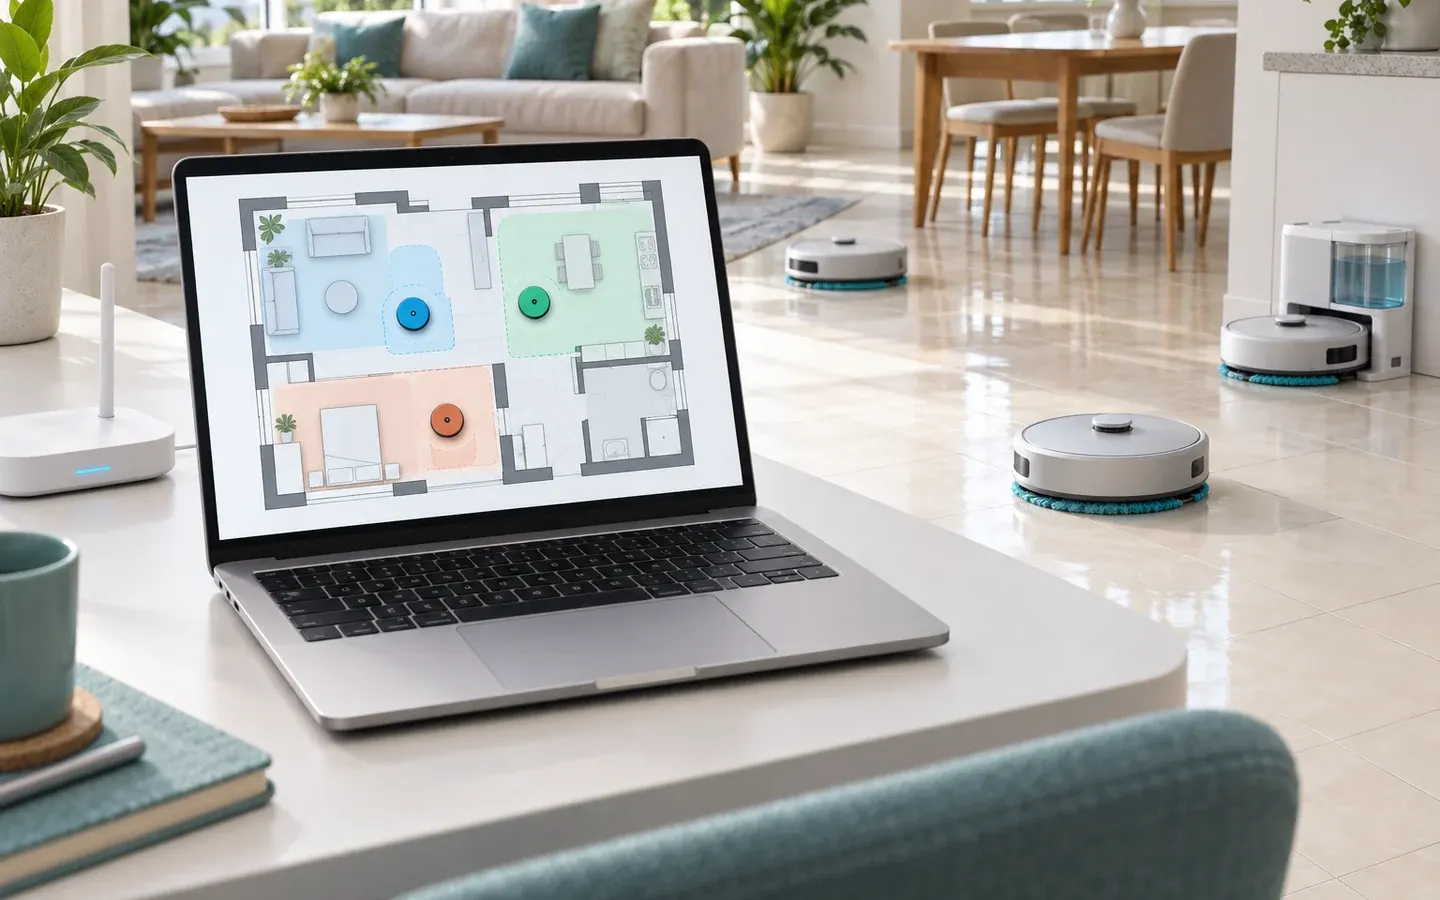 Advanced
How Can a PC Control a Fleet of Small Mopping Robots?
How a PC and small robots share work over Wi-Fi: broker or micro-ROS, message types, clock sync, failure points and how each one is noticed.
8 min read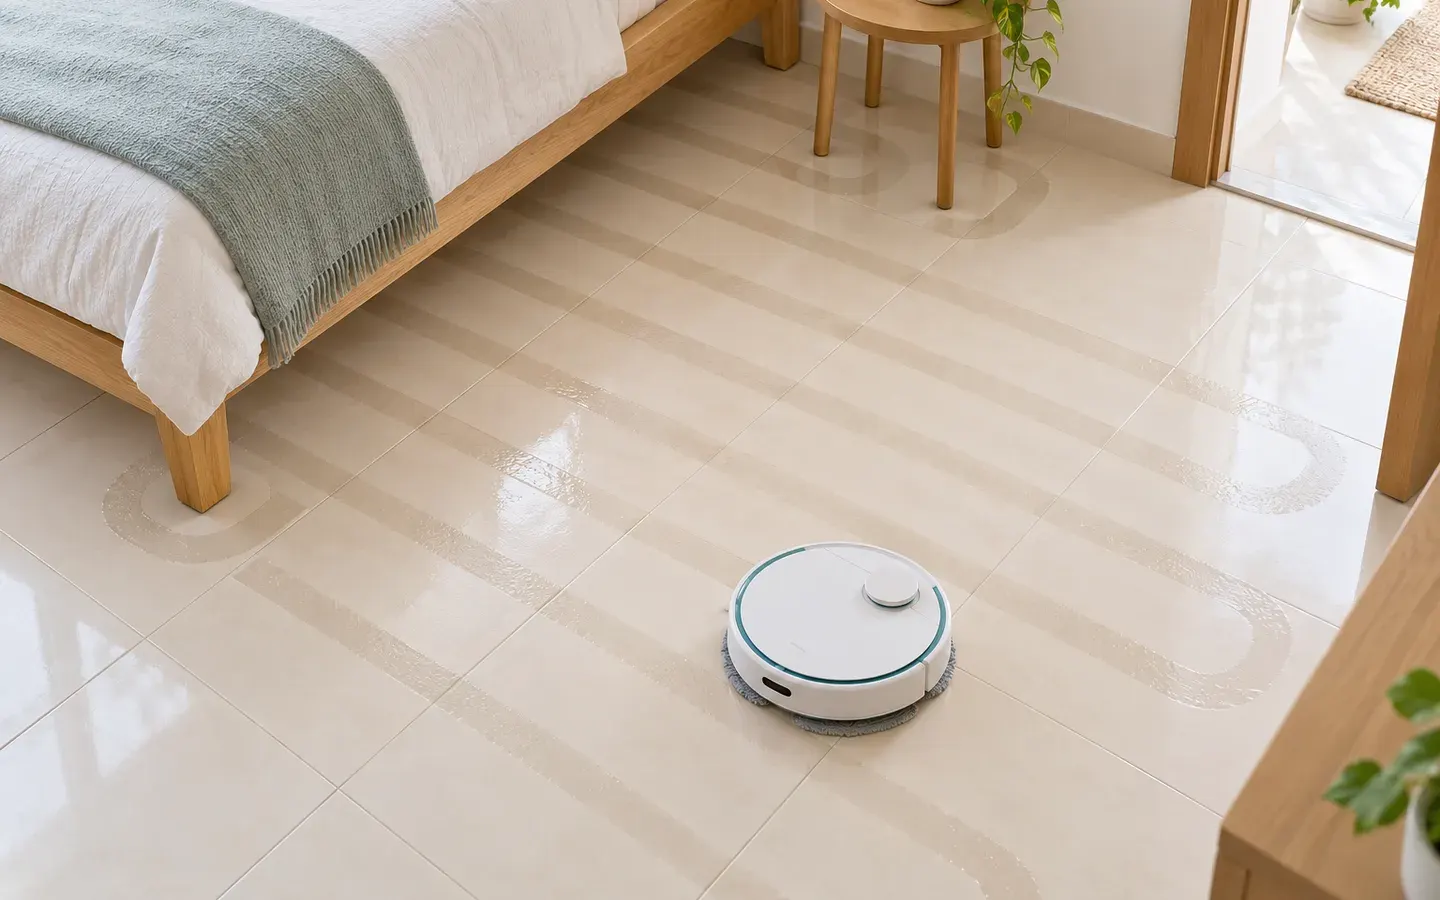 Advanced
What Path Lets a Robot Mop Cover a Whole Room?
How a mop robot covers a whole room: cells around obstacles, back-and-forth passes, a map of cleaned cells, drift correction and blocked cells.
8 min read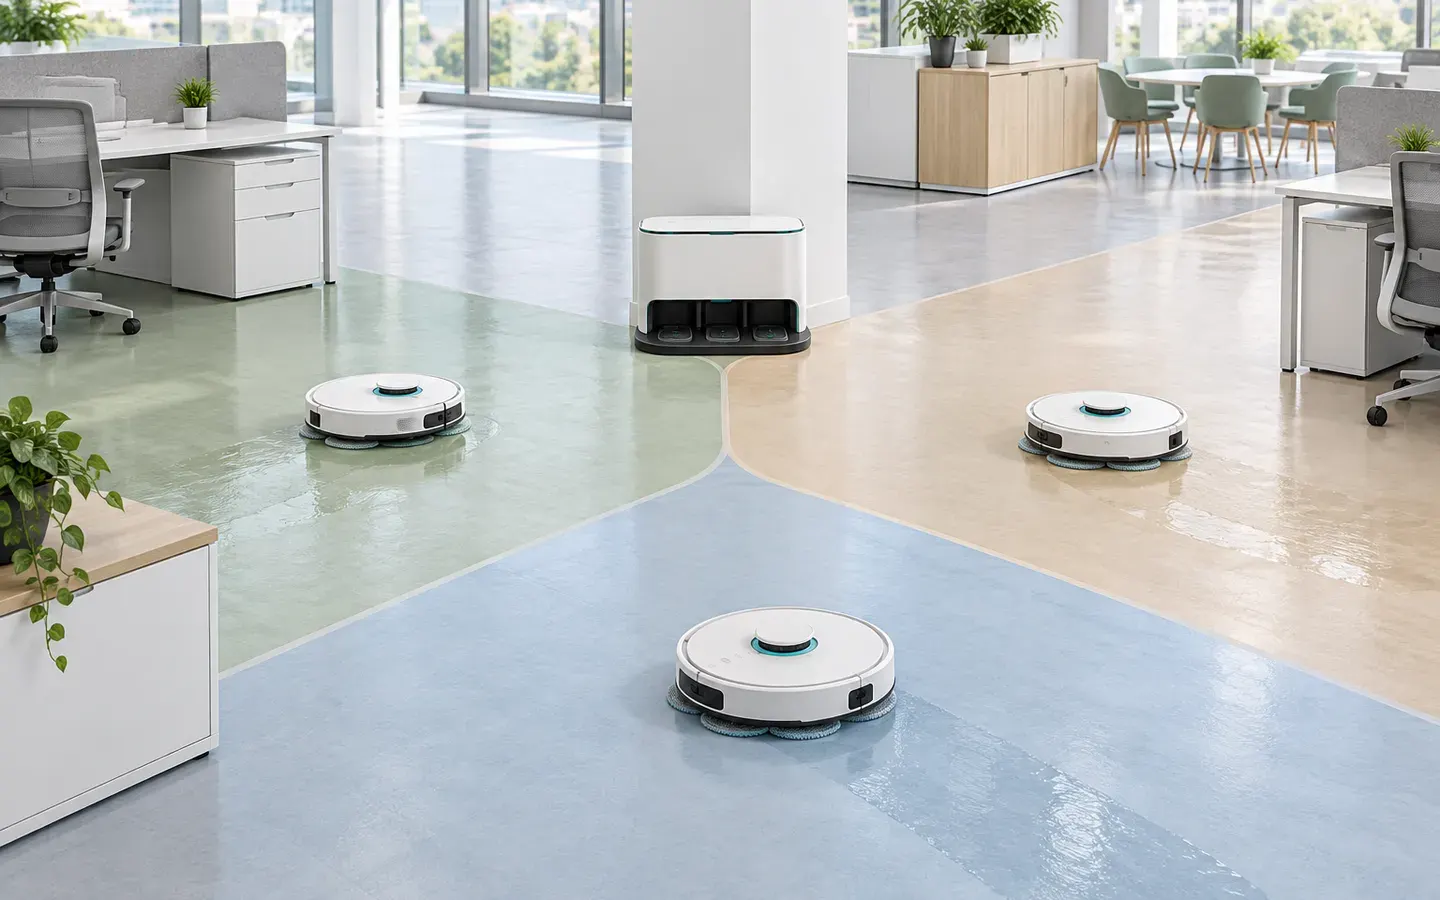 Advanced
How Do Many Mop Robots Split Zones and Share a Dock?
How a fleet of mop robots splits a floor into zones, assigns one robot to each, queues for a shared dock and hands a zone over after a failure.
8 min read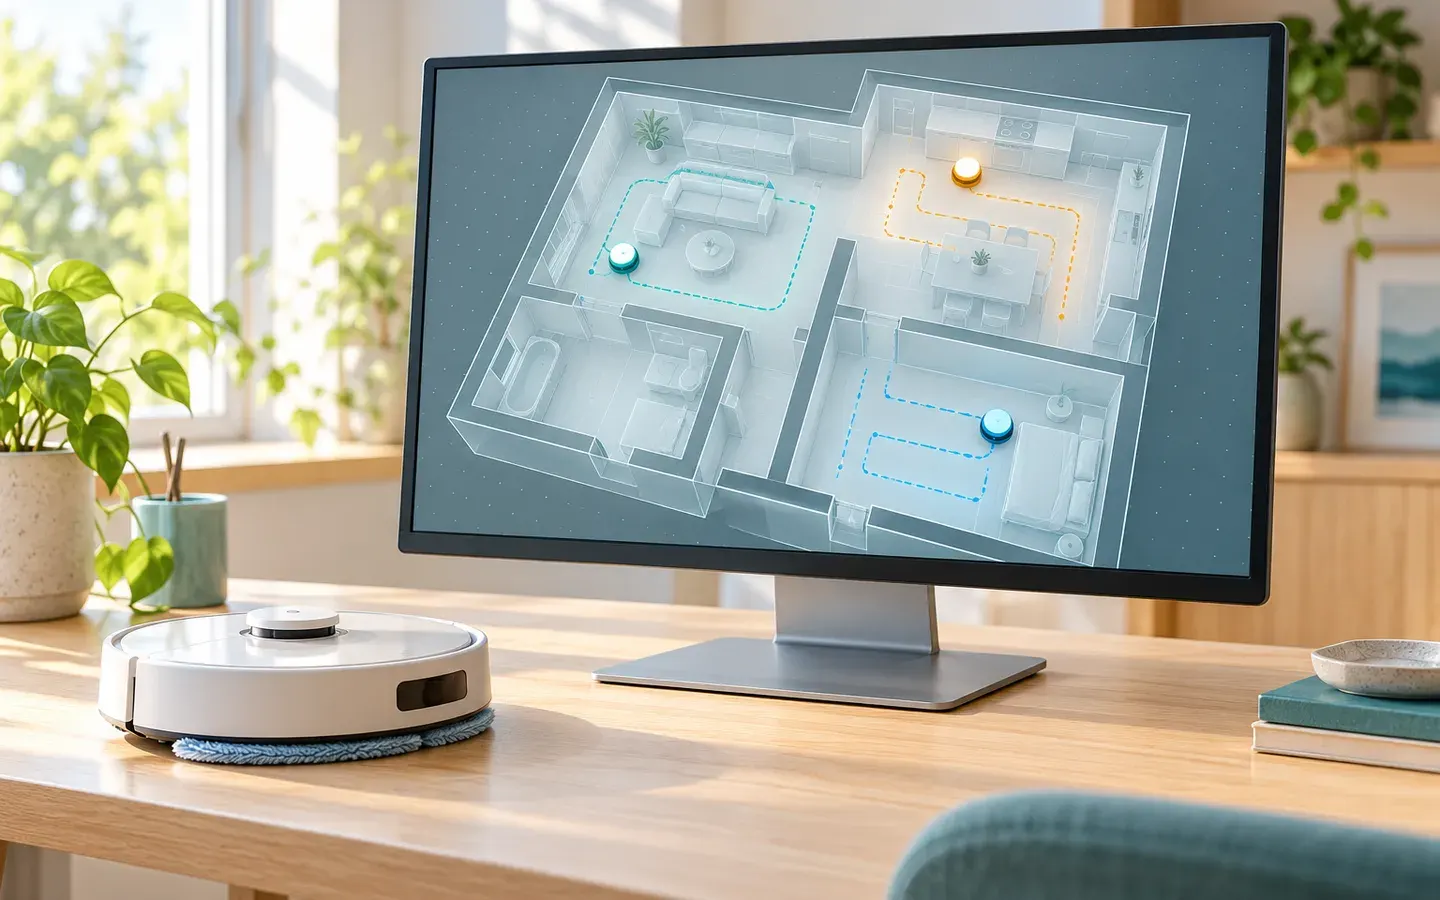 Advanced
How Do You Simulate Robot Motion in a Virtual Home?
Build a virtual home for a small mopping-robot fleet: pick a simulator, add simulated sensors, link ROS 2 and run repeated acceptance runs.
8 min read


